| 1. Confirm the applicable standard and product scope | Identify the MCB’s intended application and the applicable edition or national adoption of IEC 60898-1. | IEC 60898-1 covers air-break circuit-breakers for overcurrent protection in household and similar installations, within its stated AC voltage, current and short-circuit-capacity limits. | Use the actual product drawing, bill of materials and approved process requirements as robot inputs; the standard itself does not prescribe a particular assembly robot. | Check the product specification and compliance plan with the manufacturer’s engineering or quality team. |
| 2. Set rated current and product variants | Define the rated-current range, variant mix and changeover frequency. | For products within the title’s scope, rated current is up to 125 A. Example product variants may include 6 A, 10 A, 16 A, 20 A, 32 A, 40 A, 63 A, 80 A and 100 A; confirm the actual approved ratings for the product family. | Choose feeders, part presentation and recipe control to accommodate the required variant mix while preventing components from being loaded into the wrong product configuration. | Run a recipe-change test and verify component identity against the work order or product code. |
| 3. Specify voltage, poles and terminal configuration | Record rated voltage, pole arrangement, terminal style and the dimensions that differ between variants. | Depending on the product design, pole arrangements can include 1P, 1P+N, 2P, 3P, 3P+N or 4P. These are examples, not a universal product requirement. | Confirm gripper access, orientation, fixture spacing and whether separate tooling or robot programs are needed for different pole counts and terminal designs. | Test representative minimum- and maximum-size configurations, including terminal and enclosure clearances. |
| 4. Define the breaking-capacity and mechanism variants | Specify the rated short-circuit capacity and any mechanism, contact or arc-chute differences by model. | IEC 60898-1’s scope includes rated short-circuit capacities up to 25 kA. The value for a particular MCB must come from its approved rating and product documentation. | Design assembly and inspection steps around the actual components and process controls; do not infer breaking capacity from appearance or rated current alone. | Use part verification and traceable process records. Electrical performance testing should follow the approved test plan and applicable standard requirements. |
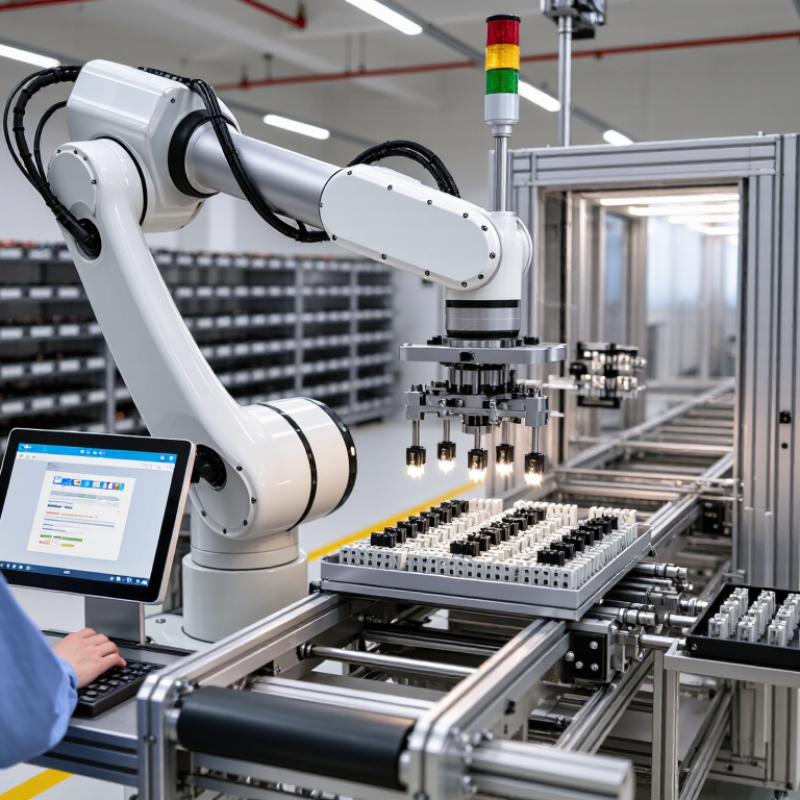
| 5. Match the robot to the assembly operations | List each operation, such as component loading, mechanism assembly, screwdriving, marking or final handling. | For each step, define part mass, position tolerance, insertion direction, fastening parameters and required cycle time from process trials. | Select robot reach, payload, repeatability, end-of-arm tooling and axis count based on the real operation and fixture layout—not on rated current alone. | Conduct a process-capability trial at the required production rate and check for missed, reversed or incorrectly seated parts. |
| 6. Build in quality checks and traceability | Identify critical-to-quality features and the records needed for each unit or batch. | Possible checks include component presence and orientation, fastener completion, marking or code readability, and dimensional or functional checks specified by the control plan. | Integrate suitable sensors, vision systems, torque monitoring and data handling where justified by the process risk and quality plan. | Challenge the inspection system with known good and deliberately incorrect samples; verify that reject handling and records work as intended. |
| 7. Plan safety, changeover and maintainability | Define operator access, safeguarding, expected uptime, maintenance access and future product changes. | Set measurable targets for changeover time, planned maintenance, spare tooling and production availability based on the factory’s operating requirements. | Compare cell layouts, guarding, interlocks, service access and modular tooling. Include the expected product variants and production volume in the evaluation. | Review the risk assessment, validate safeguarding functions, and perform a maintenance and changeover acceptance test before production release. |


 08045479132
 Send Inquiry


 Send Inquiry
 Send SMS