| Power supply and voltage class | Available AC supply, phase configuration, and the machine’s electrical limits. | Choose a drive with an input-voltage class compatible with the supply and a motor rated for that drive’s output voltage. Common industrial classes include 200–240 V AC and 380–480 V AC; actual limits vary by drive. | Confirm the feedback device is supported by the selected drive, not just by the motor. | Check the drive nameplate and manual for permitted input voltage, frequency, and phase configuration. |
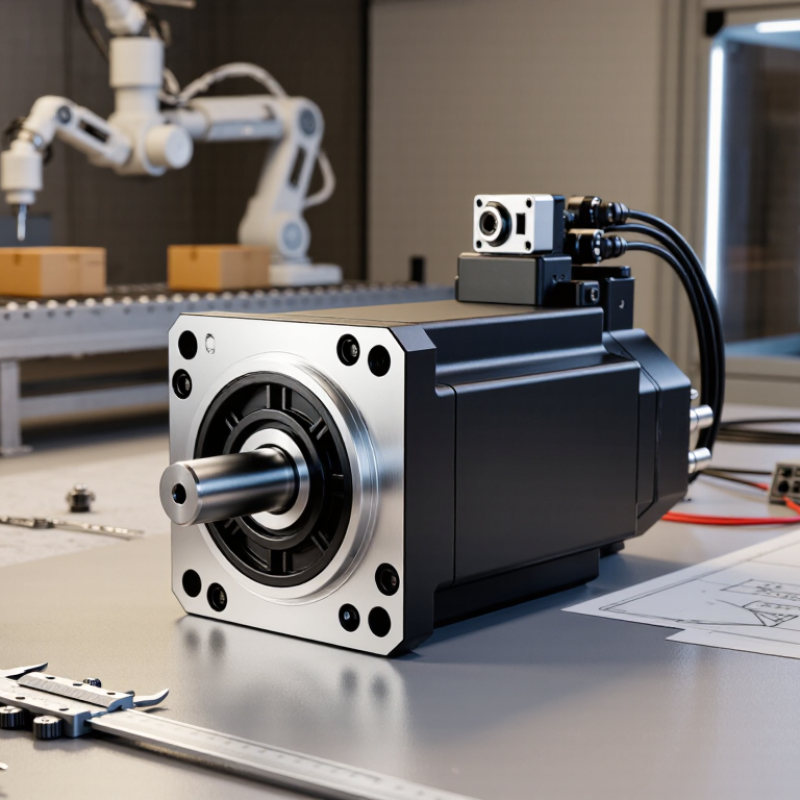
| Continuous and peak torque | Required load torque during normal operation and the highest short-duration torque during acceleration or disturbance. | The motor’s continuous torque must cover the calculated continuous requirement. Check that both motor and drive can provide the required peak torque for the required duration. | Ensure feedback and control settings support the intended torque-control or motion-control mode. | Include friction, gravity, transmission efficiency, and acceleration torque in the load estimate; do not size from rated power alone. |
| Speed and power | Required operating speed, maximum speed, and torque demand across the operating range. | Verify that the motor’s rated and maximum speeds cover the application and that the drive can supply the required current at those speeds. Mechanical power is approximately torque × angular speed. | Confirm the feedback device’s specified speed limit and the drive’s supported feedback input rate. | Review the motor torque-speed curve; available torque can decrease at higher speeds because of voltage and current limits. |
| Load inertia and acceleration | Load inertia referred to the motor shaft, acceleration time, and required stopping behavior. | Calculate acceleration torque using the total inertia referred to the motor shaft and the requested angular acceleration. Confirm the resulting peak demand is within motor and drive limits. | Position-loop performance depends on feedback resolution, update rate, and correct drive tuning. | Use the transmission ratio to reflect load inertia to the motor shaft; verify the manufacturer’s inertia and tuning guidance rather than relying on a universal inertia-ratio limit. |
| Feedback type | Whether the application needs speed feedback, incremental position, or position retained at power-off. | Select a motor and drive combination that supports the same feedback technology and electrical interface. | Incremental encoders typically provide relative position and require referencing after power-up unless another reference method is used. Absolute encoders can report position after power-up, subject to the system’s configuration and protocol. | Check encoder type, resolution, supply requirements, wiring, and whether the drive can read the specific feedback device. |
| Feedback protocol and commutation | Encoder signal format or serial protocol, plus the signals needed for motor commutation. | Drive support must explicitly include the motor’s feedback interface; matching connector shape alone does not establish compatibility. | Incremental A/B/Z signals, Hall signals, resolver signals, and serial absolute-encoder protocols are not interchangeable. Serial protocols may be implementation-specific. | Confirm the exact protocol, pinout, cable and connector requirements, and any required motor-identification or commutation data in the drive documentation. |
| Mounting and environment | Frame size, shaft and flange dimensions, installation orientation, ambient temperature, and exposure to dust or moisture. | Match mechanical dimensions and confirm the drive and motor are rated for the machine’s electrical and thermal conditions. | Check feedback-device temperature limits and cable routing requirements, especially near power cables or other sources of electrical noise. | Verify the motor’s enclosure rating, allowable ambient conditions, cooling method, and mounting dimensions against the application. |
| Holding brake and safety | Whether the axis must hold position when stopped or when motor power is removed. | If a brake is required, confirm the motor includes a compatible brake and that the drive or control system provides the correct brake-control arrangement. | Feedback indicates position; it does not mechanically hold the load. A motor brake is generally intended for holding, not repeated dynamic stopping unless specifically rated for it. | For vertical or gravity-loaded axes, assess the risk of load movement and follow the machine’s braking and safety requirements. |


 08045479132
 Send Inquiry


 Send Inquiry
 Send SMS